Cobots: How Collaborative Robots Work Safely Beside Humans
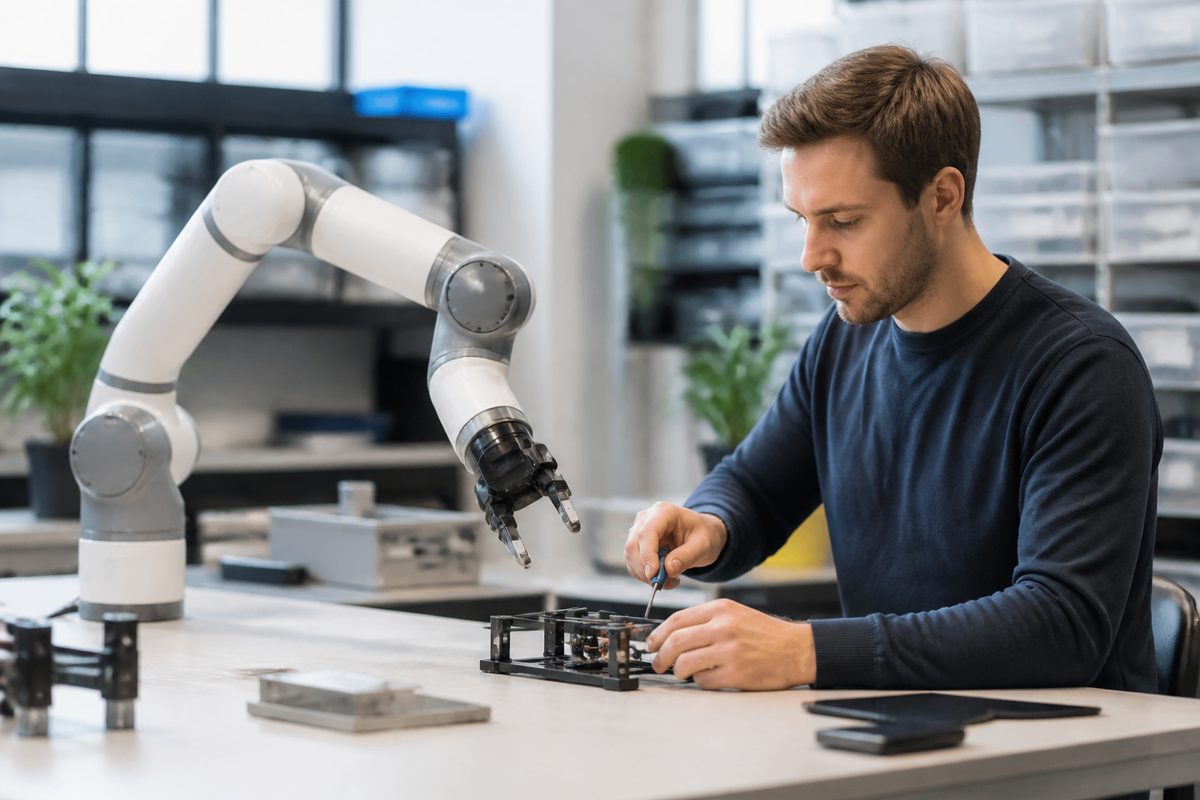
What makes a cobot different from a traditional industrial robot, how force sensing and safety design work, and where collaborative robots fit best.
What makes a cobot different from a traditional industrial robot, how force sensing and safety design work, and where collaborative robots fit best.
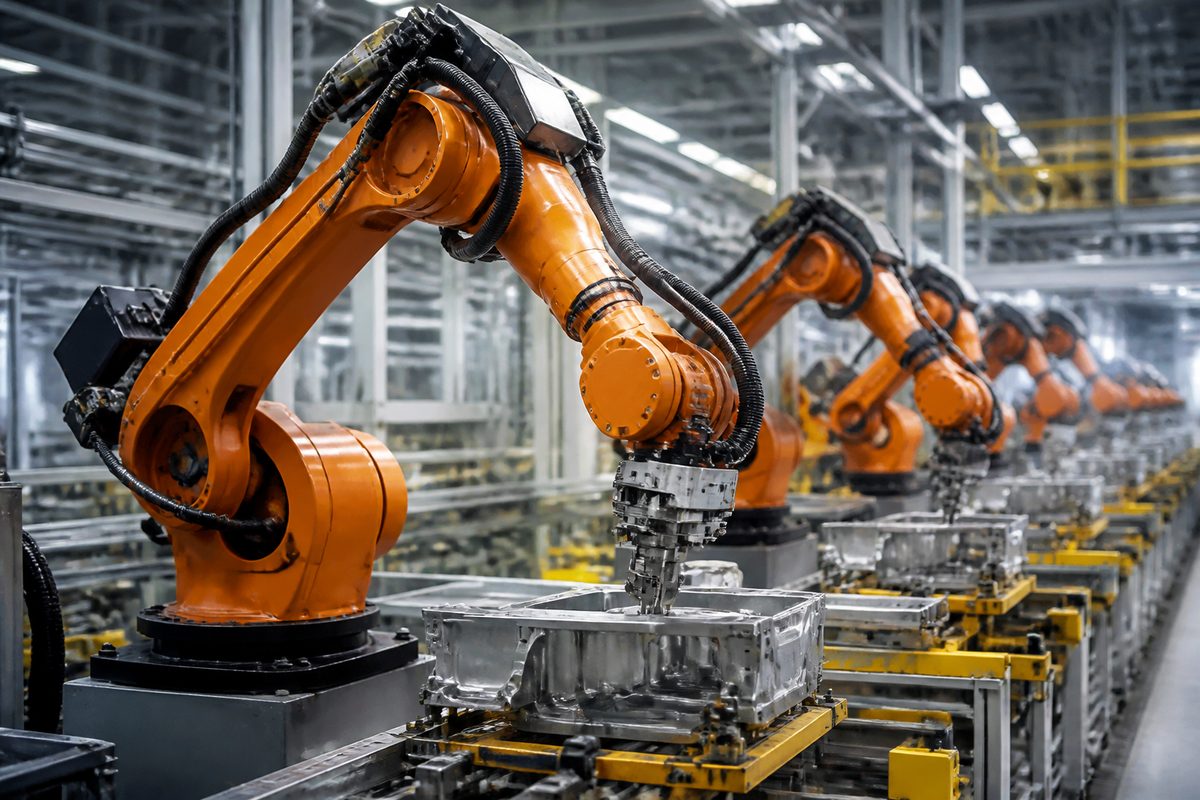
A clear guide to the six main types of industrial robots — articulated, SCARA, delta, cartesian, cylindrical, and polar — and the jobs each does best.